HUMATRIX — AI technologies for humanoid robotsin
UBTECH · INDUSTRIAL WHEELED HUMANOID

Cruzr Y1

Intelligence that moves industry.

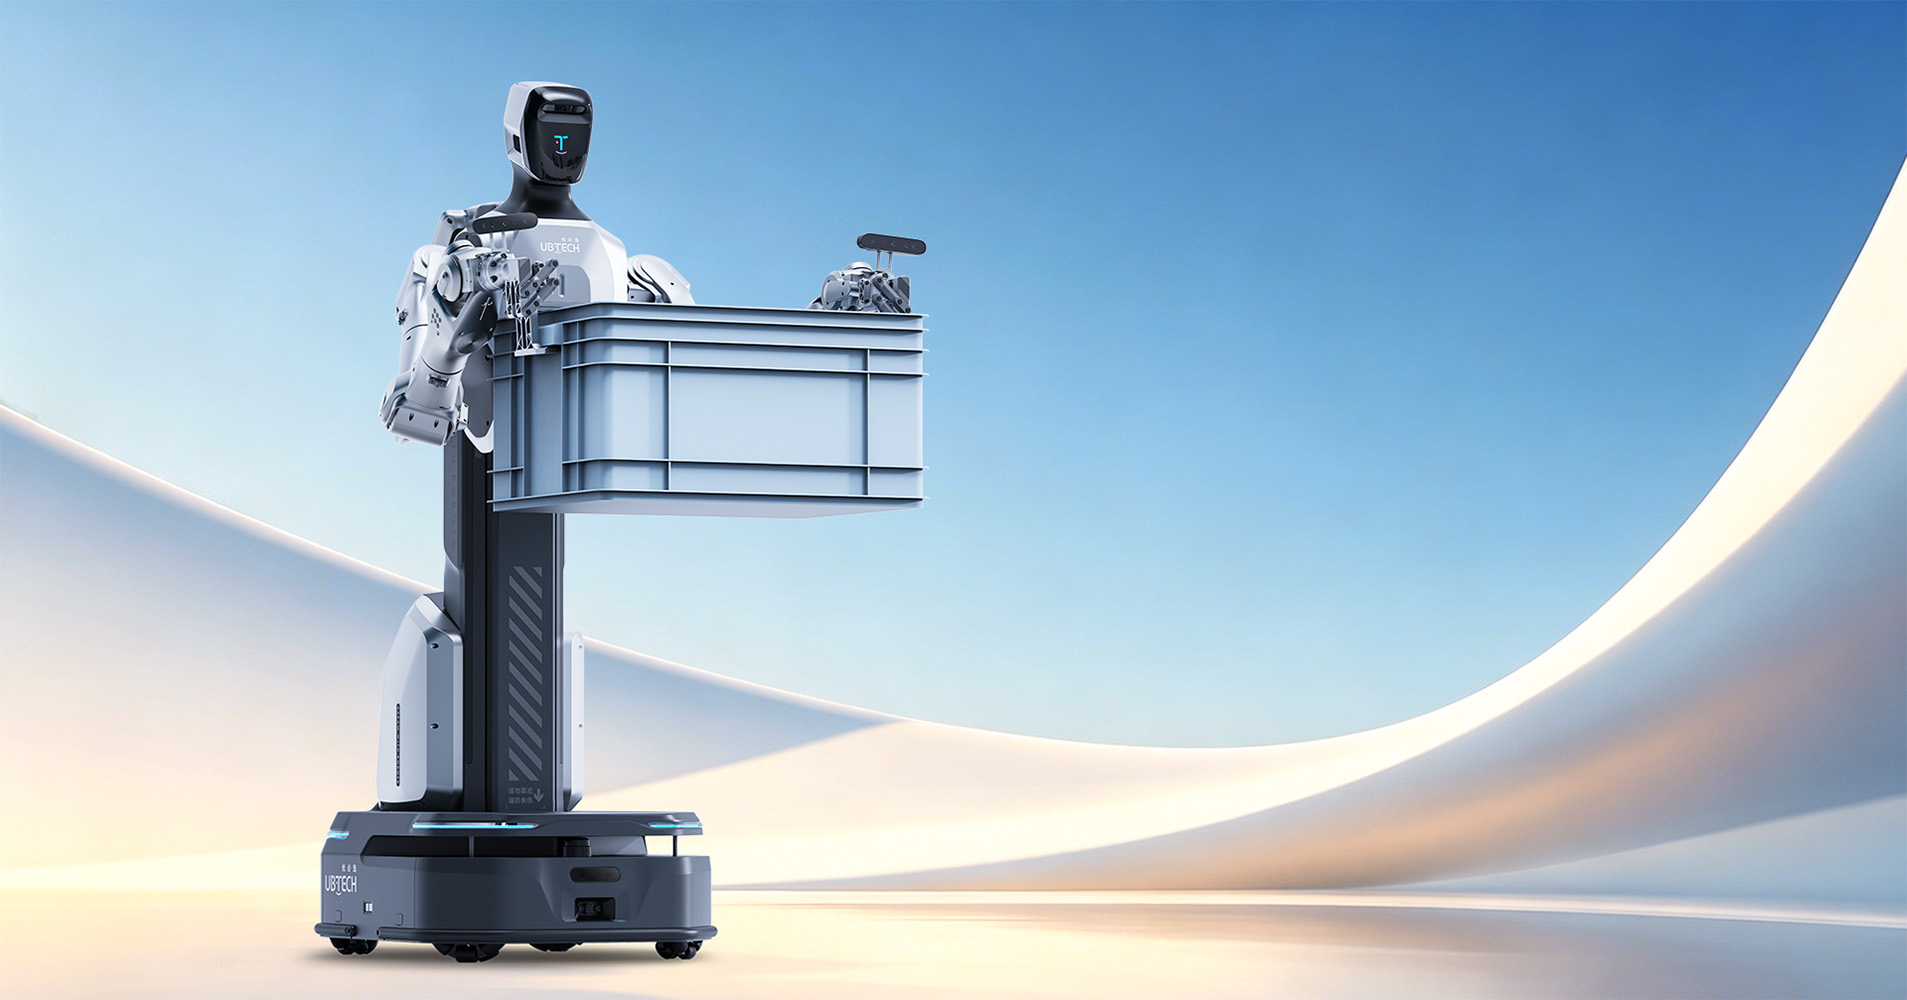
Cruzr Y1 combines omnidirectional mobility, two anthropomorphic arms and embodied intelligence to connect warehousing, manufacturing and logistics. It perceives its surroundings, plans tasks and handles materials on a mobile industrial platform.

UBTECH Cruzr Y1
10 kgCombined payload of both arms
±0.5 mmHandling repeatability
0–1.8 mVertical reach
> 4 hBattery runtime

From movement to intelligent execution.

Coordinated mobility, handling and perception for industrial tasks. Configuration and operational performance are validated in your environment.

01

Two arms, more possibilities

Each arm has 7 degrees of freedom and a 750 mm reach. The anthropomorphic design supports approaching, grasping and placing materials at different stations. The advertised payload is 10 kg for both arms combined.

UBTECH context · multiple models →
02

Omnidirectional mobility

The base can rotate 360° on the spot. UBTECH advertises navigation through 0.8 m aisles; actual clearance depends on the route, posture and materials carried.

UBTECH context · multiple models →
03

Task-specific grippers

The modular quick-change system supports tools for cartons, bins and irregular parts. Grippers, fingers and included accessories must be defined in the proposal.

UBTECH context · multiple models →
04

Multimodal perception

LiDAR, ToF, RGB and force sensors help interpret space, locate objects and guide handling. The platform includes 360° LiDAR perception and voice interaction.

UBTECH context · multiple models →
05

Planning with embodied AI

The perception, decision, grasp and placement chain supports planning and executing work sequences. UBTECH Co-Agent supports industrial task coordination.

UBTECH context · multiple models →
06

Energy and operation

Over 4 hours of battery runtime and fast charging under 1.5 hours, according to the manufacturer. Quick battery swapping and automatic charging support a continuous-operation strategy.

UBTECH context · multiple models →
UBTECH · OFFICIAL VIDEOS

Cruzr Y1 · See the robots in action

Official videos organised by model and demonstration.

These videos present the ecosystem and several UBTECH robots. They are not exclusive demonstrations of this model; its specifications are listed in the technical sheet.

UBTECH context · multiple models

Swarm intelligence in action

Coordination between robots presented by UBTECH.

Open official video ↗
UBTECH context · multiple models

UBTECH range at WRC 2026

An overview of several robots and manufacturer demonstrations.

Open official video ↗
UBTECH context · multiple models

Five humanoids at WRC 2025

A combined range presentation; consult each model’s technical sheet.

Open official video ↗
More videos on the UBTECH channel ↗

One platform. Multiple points in the operation.

Applications presented by UBTECH. Tools, machine integration and cycle times are assessed for each project.

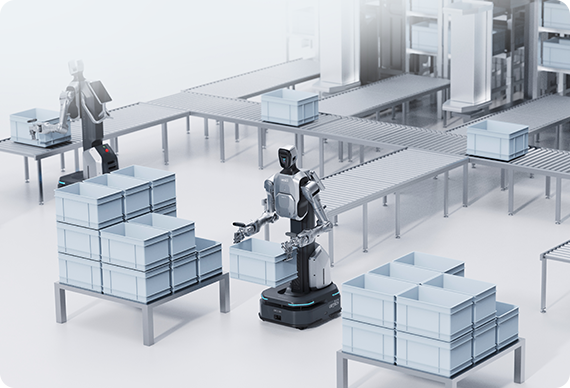
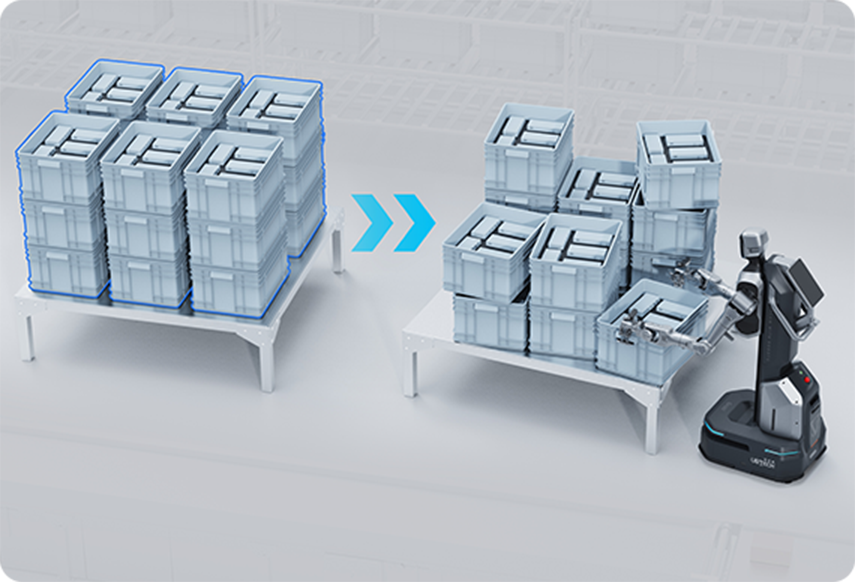
Cruzr Y1 · industrial palletising

Autonomous palletising

Carton handling that adapts to box dimensions and connects with line workflows. Pallet patterns, weights and throughput must be tested using your materials.

Cruzr Y1 · adapting to displaced loads

Adapting to displaced loads

Perception and planning support responses to misaligned materials or disorganised loads. Exception recovery is assessed during the pilot.

Cruzr Y1 · material sorting

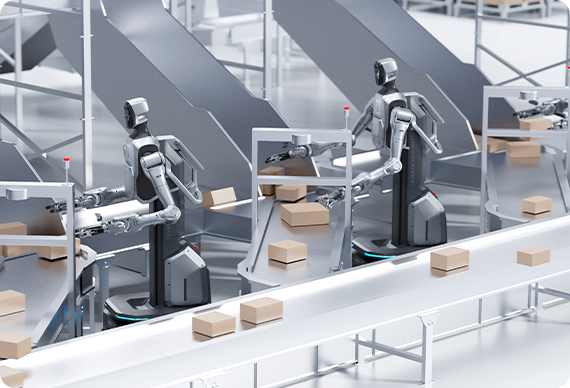
Material sorting

Sorting and handling mixed, unordered or irregular materials. Assessment covers recognition, grasp success and placement.

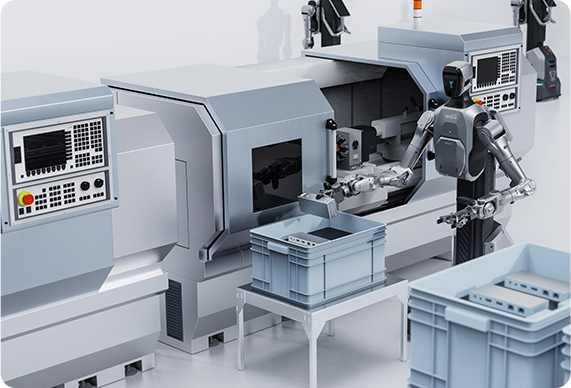
Cruzr Y1 · machine tending

Machine tending

Loading and unloading CNC and moulding machines in coordination with work cycles. Integration must address machine signals, access, tools and safety.

Cruzr Y1 technical specifications

Values published on the official UBTECH page reviewed on 30 September 2026. Advertised values do not replace application validation.

ParameterValue / capabilityHow to interpret it
ArchitectureMobile industrial wheeled humanoidTwo-arm handling with a mobile base.
Degrees of freedom7 per arm14 across both arms; not the total for the entire robot.
Arm reach750 mmAdvertised arm reach; separate from vertical reach.
Dual-arm payload10 kg, combinedDo not interpret as 10 kg per arm.
Repeatability±0.5 mmAdvertised handling value; not navigation accuracy.
Vertical reach0–1.8 mAdvertised vertical working range.
MobilityOmnidirectional; 360° rotation on the spotTravel and station approach.
Aisles0.8 m, according to UBTECHValidate clearance, turns, posture, obstacles and payload.
Battery runtimeOver 4 hoursActual duration depends on tasks and conditions.
Fast chargingUnder 1.5 hoursAdvertised manufacturer value.
Energy managementQuick battery swapping and automatic chargingSupports 24/7 planning; does not mean 24 hours on one charge.
ToolsModular quick-change grippersSelected to match materials and tasks.
PerceptionLiDAR, ToF, RGB and force sensorsMultimodal information for surroundings and handling.
Interaction and operationTouchscreen, voice and ergonomic handleManage tasks, maps, skills and devices; manual push movement.
Industrial intelligenceAutonomous planning and UBTECH Co-AgentPerception → decision → grasp → place.

Dimensions, mass, top speed, battery chemistry, environmental limits, integration interfaces and certifications must be confirmed in documentation for the proposed configuration. These are not detailed on the official page reviewed.

From robot capabilities to factory results.

HUMATRIX assesses the use case and prepares a technical and commercial configuration for Portugal and Spain.

01

Define the task

Objects, weights, dimensions, source, destination, throughput and process exceptions.

02

Validate the environment

Floor, aisles, turns, stations, charging areas and pedestrian routes.

03

Select tools and connections

Grippers, accessories, machine communication and potential production or warehouse system integration.

04

Run a pilot

Measure cycle times, availability, success rate, fault recovery and quality.

05

Prepare operations

Risk assessment, procedures, training, maintenance and charging strategy.

Frequently asked questions

Can Cruzr Y1 lift 10 kg with each arm?

No. The official page presents 10 kg as the combined payload of both arms. Load distribution, tooling and posture must be checked for the task.

Does ±0.5 mm refer to navigation accuracy?

No. This is the handling repeatability advertised by UBTECH. Base positioning accuracy and process tolerance must be confirmed separately.

Can it work for 24 hours without charging?

That is not the manufacturer’s claim. Advertised battery runtime exceeds 4 hours. Continuous operation depends on a quick battery swapping and automatic charging strategy.

Is battery swapping autonomous, like Walker S2?

The Cruzr Y1 page mentions quick swapping and automatic charging. It does not confirm autonomous battery swapping; that is not presented here as a Y1 specification.

Does a 0.8 m aisle work for every task?

It is an advertised capability, not a universal guarantee with any payload. Turns, clearance, obstacles, arms, tools and materials need route-specific validation.

Are five-finger hands included?

The official source presents modular tools. The gripper or hand type and included accessories must be confirmed in the configuration and commercial proposal.

Can it connect to my CNC or warehouse system?

That integration must be assessed. The proposal needs to identify interfaces, signals, sequences, equipment and safety responsibilities; immediate compatibility with every system is not assumed.

How do 750 mm and 1.8 m differ?

750 mm is the advertised arm reach. 0–1.8 m is the platform’s advertised vertical reach. These are different measurements that must be assessed against actual task geometry.

Configuration and commercial proposal

HUMATRIX indicative price

Shall we assess Cruzr Y1 in your operation?

Share your task, materials and objectives. A useful proposal starts with a well-defined application.

Request a technical proposal →

Official technical and image source: UBTECH · Cruzr Y1 ↗
Information verified on 30/09/2026.