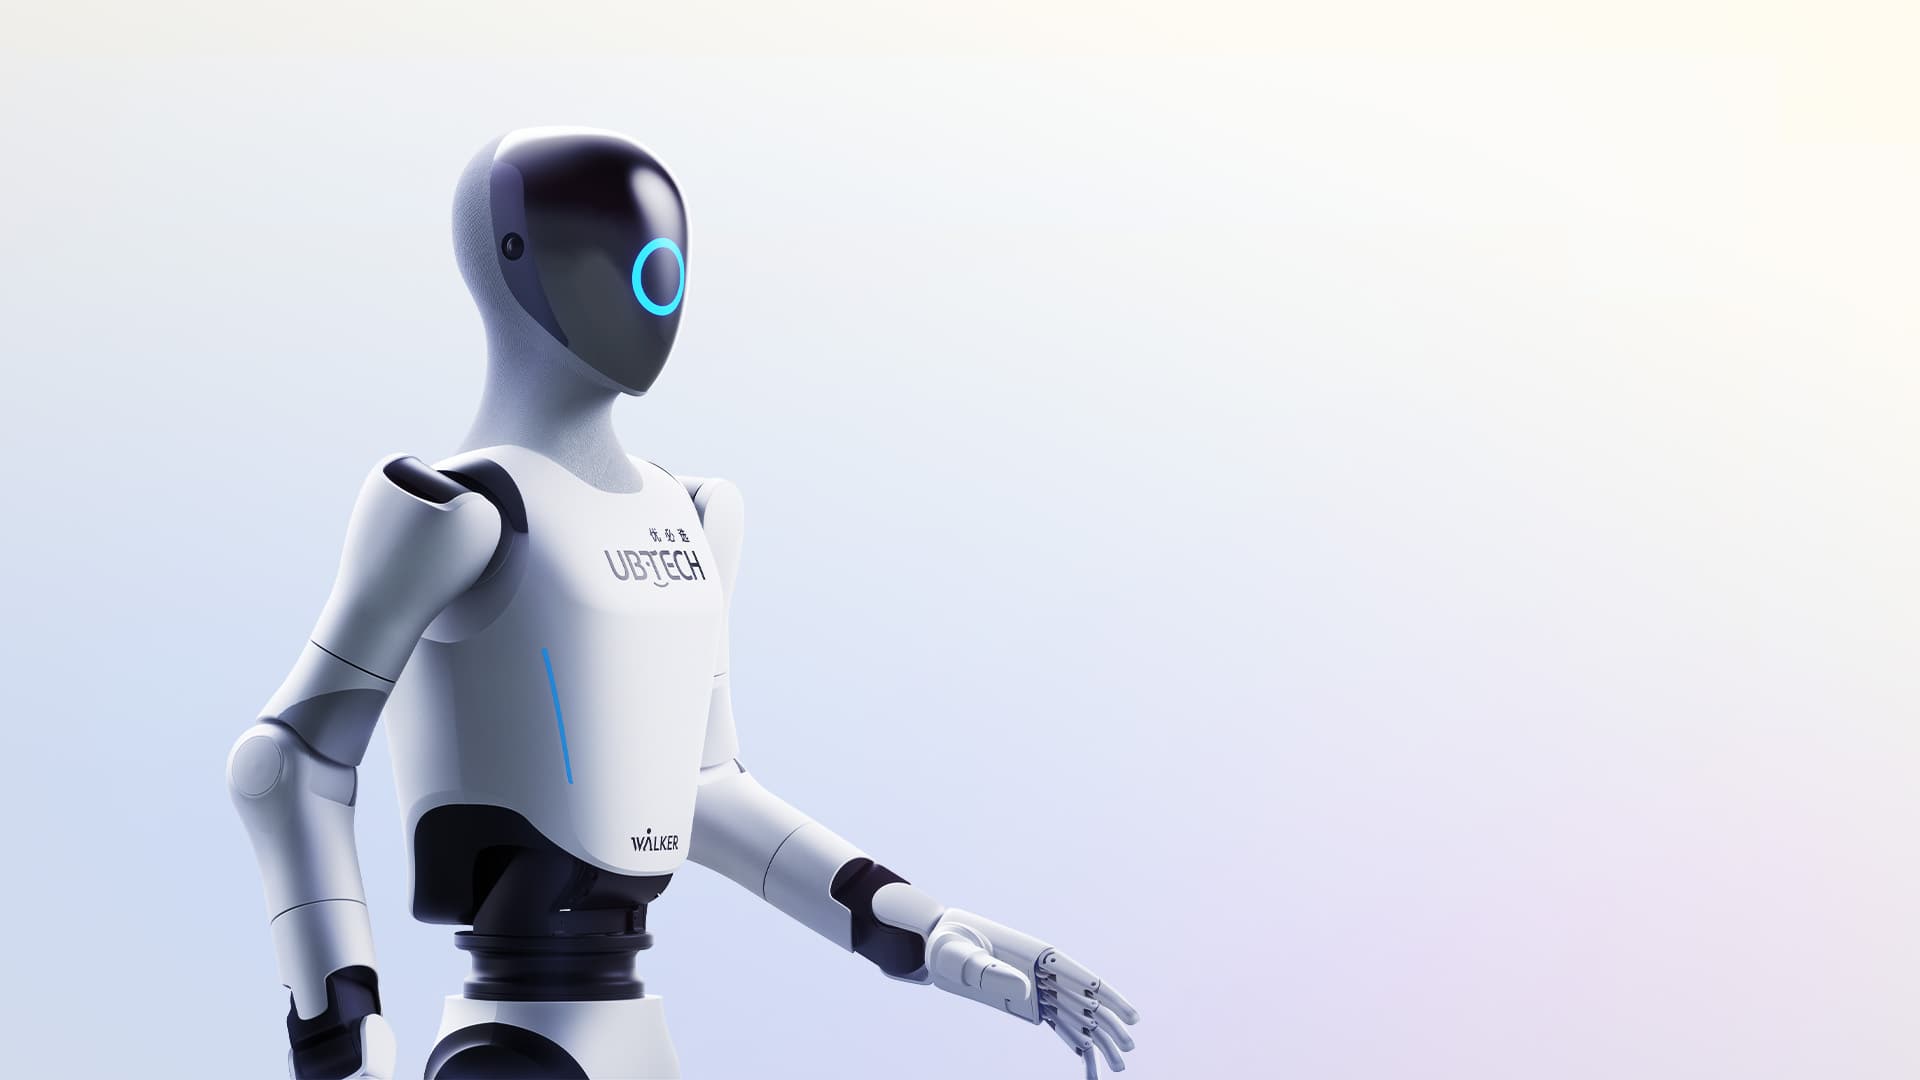
Full-body humanoid
With an advertised height of 164 cm, mass of 55 kg and 53 degrees of freedom, C1 uses legs and body joints for expressive postures and motion. Hand configuration must be confirmed.
Watch video →Humanoid presence. Intelligent service.
Walker C1 is a full-size bipedal humanoid for reception, guidance, cultural experiences and research. It combines expressive motion, multimodal perception and embodied intelligence in a platform open to customisation.
Walker C1 is designed for urban and commercial services. It combines bipedal locomotion, AI models, a motion library and development interfaces.
With an advertised height of 164 cm, mass of 55 kg and 53 degrees of freedom, C1 uses legs and body joints for expressive postures and motion. Hand configuration must be confirmed.
Watch video →UBTECH presents walking, running, dancing and dynamic balance on one or both feet. A motion library and customisable control support task-specific gestures and sequences.
Watch video →Multimodal language models, VLN/VLA and Thinker-WAM link perception, language, navigation and action. A custom knowledge base and spatiotemporal memory support adapted content.
Watch video →The official source advertises NVIDIA Jetson Thor with 2070 TFLOPS at FP4, local offline operation and cloud compatibility. Models, functions and network requirements are defined in the configuration.
Watch video →Real-time 3D mapping, centimetre-level obstacle detection and full-body obstacle avoidance are manufacturer-presented capabilities. Routes and pedestrian interaction are validated on site.
Watch video →Standard interfaces and a comprehensive SDK support application development. The advertised framework is Thinker + Control Center + ROSA 2.0; actual access and version are confirmed in the proposal.
Watch video →Official videos organised by model and demonstration.
An official Walker C1 movement demonstration.
Open official video ↗Four application areas presented by UBTECH. Scripts, routes, languages and integrations are prepared for the space and audience.
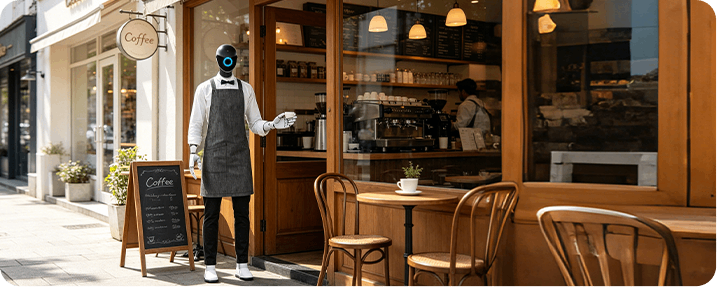
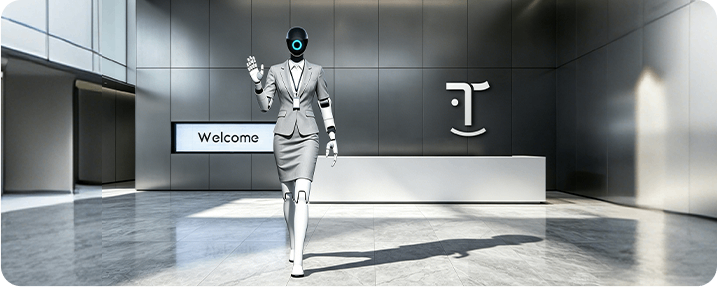
Multilingual reception, AI tours and shopping assistance. HUMATRIX defines knowledge, content, destinations and criteria for handing over to a person.
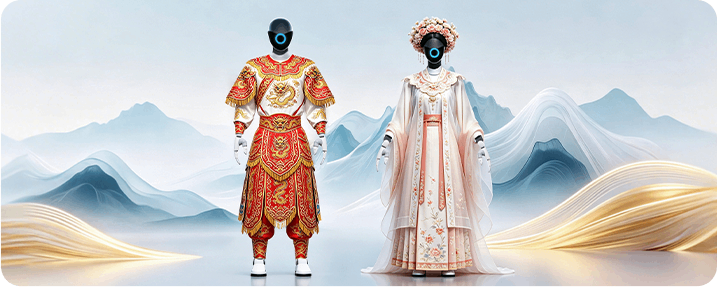
Events, themed performances and visitor interaction. Gestures, choreography and dialogue are prepared with suitable supervision and operating zones.
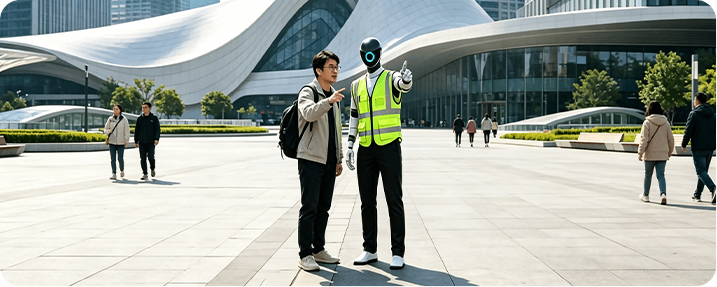
UBTECH presents patrol inspection and traffic assistance as applications. Routes, inspection functions and integration with the location must be validated for the project.
Teaching assistance and a development platform. Universities and laboratories can assess interaction, perception, navigation and control using available interfaces and tools.
Official UBTECH diagram. Dexterous hands are labelled optional; components are described in the specifications below.
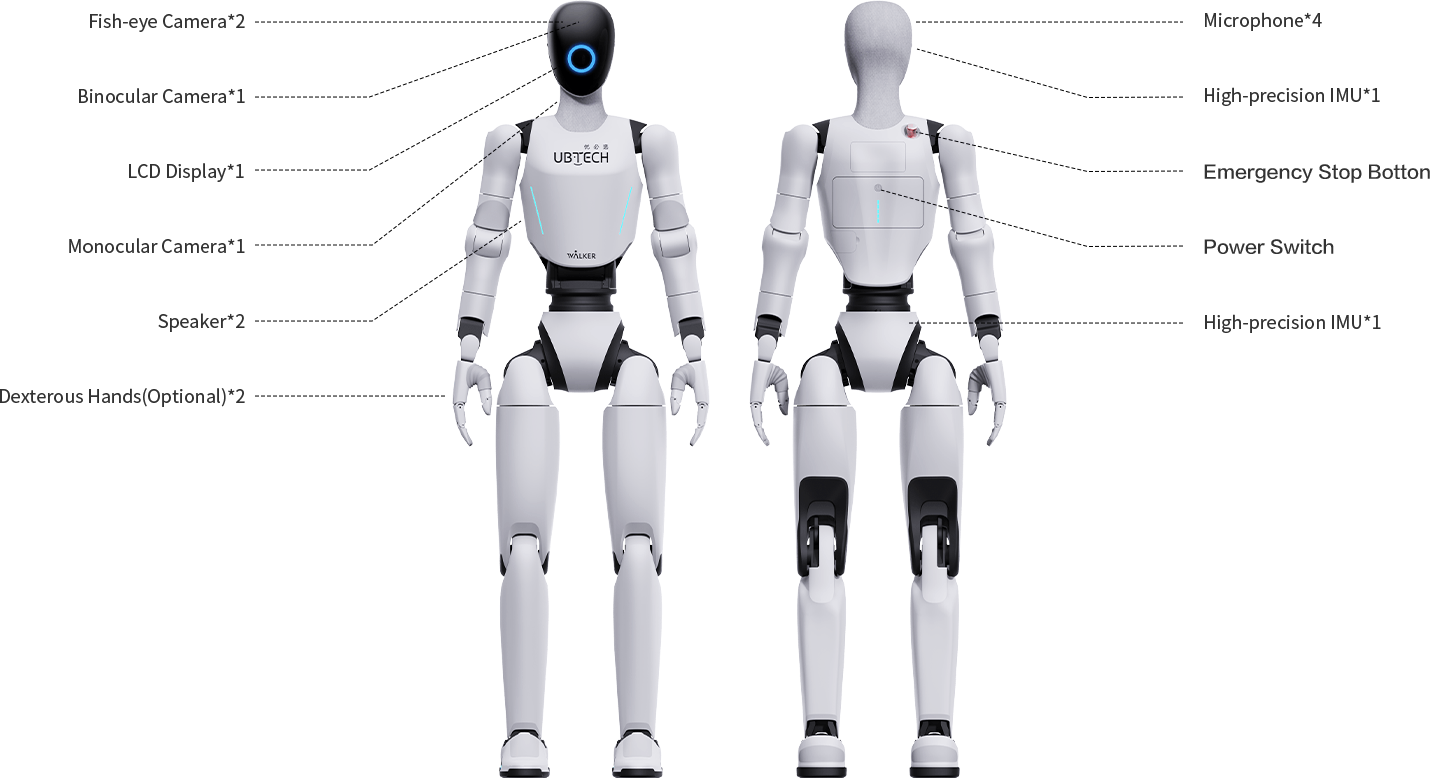
Data and capabilities published by UBTECH, including official infographics. Reviewed on 30 September 2026; final configuration subject to confirmation.
| Parameter | Value / capability | Context |
|---|---|---|
| Architecture | Full-size bipedal humanoid | Legged service platform, distinct from a wheeled robot. |
| Height | 164 cm | Value published in the design infographic. |
| Mass | 55 kg | Advertised manufacturer value. |
| Degrees of freedom | 53 DoF | Advertised total; confirm configuration and optional hands. |
| Motion | Walking, running and dancing | Motion library and customisable control. |
| Advertised speed | ≥ 3 m/s | Dynamic-agility figure; not a recommended speed around visitors. |
| Balance | Dynamic, on one or both feet | Full-body trajectory tracking. |
| Computing | NVIDIA Jetson Thor · 2070 TFLOPS (FP4) | Advertised compute capacity; FP4 is the stated precision format. |
| Models and intelligence | Multimodal LLM, VLN/VLA and Thinker-WAM | Language, navigation, action and world model. |
| AI operation | Local offline and cloud-compatible | Function availability and integration confirmed per project. |
| Knowledge and memory | Custom knowledge base and spatiotemporal memory | Content, updates and data handling defined during deployment. |
| Navigation | Real-time 3D mapping and full-body obstacle avoidance | UBTECH advertises centimetre-level low-obstacle detection and automatic emergency braking. |
| Cameras | 2 fisheye + 1 binocular + 1 monocular | Equipment identified in the official diagram. |
| Audio | 4 microphones and 2 speakers | Quantities shown in the official diagram. |
| Display | 1 LCD | Identified in the official diagram. |
| Inertial sensors | High-precision IMUs | The diagram identifies two modules at separate locations. |
| Dexterous hands | 2 optional hands | Manufacturer-labelled optional accessory. |
| Safety and control | Emergency stop, force control and anti-fall protection | UBTECH presents an independent safety controller and fail-safe protection; validate documentation and application. |
| Software and development | Standard interfaces, SDK; Thinker + Control Center + ROSA 2.0 | Confirm version, access, licences and contracted documentation. |
| Design and deployment | Modular architecture and configurable appearance | UBTECH mentions cross-model compatibility, outfit customisation and single-person deployment. |
Battery runtime, charging time, payload, packaging dimensions, IP rating, environmental limits, available languages and applicable certifications are not detailed on this official page. They must be confirmed for the proposed configuration. Motion capabilities do not replace route and human-interaction assessment.
HUMATRIX prepares the use case, configuration and integration plan for Portugal and Spain.
Audience, location, objectives, schedules, tasks and interaction boundaries.
Scripts, FAQs, knowledge base, tone and human handover rules.
Floor, obstacles, audience, clearance, motion and emergency procedures.
Interfaces, content, updates and potential external systems.
Pilot with interaction, availability and quality metrics; training and ongoing support.
No. The official page presents a full-body legged humanoid capable of walking, running and dancing.
53 DoF is UBTECH’s advertised total. Dexterous hands are labelled optional; joint distribution and accessories must be confirmed for the contracted version.
UBTECH presents multilingual reception but does not list every supported language. Portuguese, Spanish and other required languages must be confirmed and tested in the proposal.
The manufacturer presents local offline operation and cloud compatibility. This does not mean every function works without a network: models, knowledge, updates and integrations are defined per project.
The ≥ 3 m/s figure appears in the dynamic-agility presentation. Operating speed, clearance and motion around visitors must be defined for the space and application.
The official page reviewed does not publish battery runtime or charging time. These must be confirmed for the proposed configuration without importing values from other models.
UBTECH presents standard interfaces and a comprehensive SDK. The proposal must confirm access, licences, tools, software version and documentation.
The official source labels them optional. Configuration, accessories and services included in the commercial price must be itemised in the HUMATRIX proposal.
HUMATRIX indicative price
Share your space, audience and goals. We will prepare a configuration and proposal suited to your service.
Official technical, video and image source: UBTECH · Walker C1 ↗
Information verified on 30/09/2026.